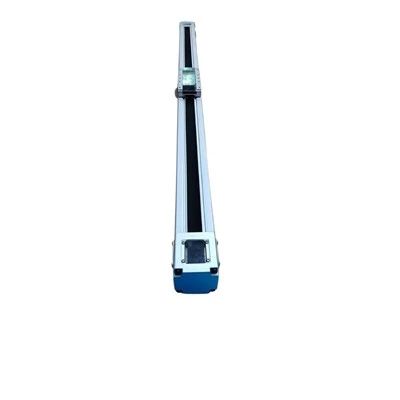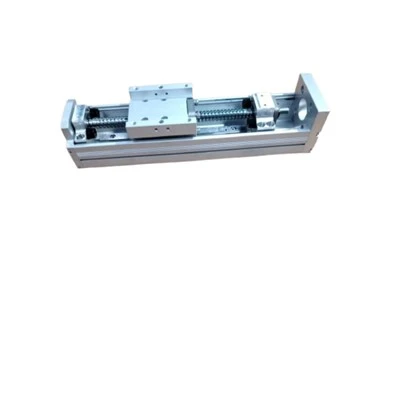
Left-Angle Mount Crawler-Type Linear Modules
Torsional Rigidity in Cantilevered Pick-and-Place

Crawler-Type Linear Modules

Left-Angle Mount Design

Cantilever Pick-and-Place Axis
- Download 3D CAD (.STEP) models for crawler-type linear modules to run your dial table layout simulation before mechanical design freeze.
- Left-angle motor mounting relocates the servo drive laterally instead of axially, reducing overall installation width by 37% for multi-station cam index dial layouts. The crawler toothed-belt drive achieves multi-tooth meshing with zero transmission slippage, while wide-base linear guide extrusion suppresses pitch and yaw deflection under cantilever moment loads. This mechanical configuration maintains positional repeatability within ±0.01mm at cycle times below 0.75s for miniature relay component handling.
| Parameter | Crawler Belt Drive (Left-Angle Module) | Standard Open Toothed Belt | Ball Screw Drive |
|---|---|---|---|
| Positional Repeatability | ±0.01 mm | ±0.03 mm | ±0.005 mm |
| Max Linear Speed | 3.2 m/s | 2.8 m/s | 1.2 m/s |
| Allowable Pitch Moment | 215 N·m/rad | 120 N·m/rad | 280 N·m/rad |
| Anti-Slippage Performance | Zero slip (multi-tooth mesh) | Risk of tooth jump under high acceleration | No slip |
| Maintenance Interval | 12,000 operating hours | 8,000 operating hours | 15,000 operating hours |
| Relative Capex | Medium | Low | High |
Pair this axis with our high-speed PPU pick-and-place manipulators for full relay material handling automation.